RENLABENDOSCOPIC AUTONOMY Chi Kit Ng

Robotic endoscopy · CUHK

From instruction
to action.

Learning to see, navigate and improve.
We build intelligent policies for flexible endoscopic robots.

Vision + languageRobot learningPhysical evidence
IN THE LAB01 / TARGET ACQUISITION
LANGUAGE-GUIDED EXPLORATIONEndoVLA-OOV
↗

12-second research preview · Watch the full demonstration

01Perceive

Connect visual observations with language.

02Navigate

Turn intent into motion through interaction.

03Improve

Learn from evidence in the physical world.

The research collection

Small views.
New possibilities.

Six projects exploring how endoscopic robots
perceive, act and learn.

06 projects
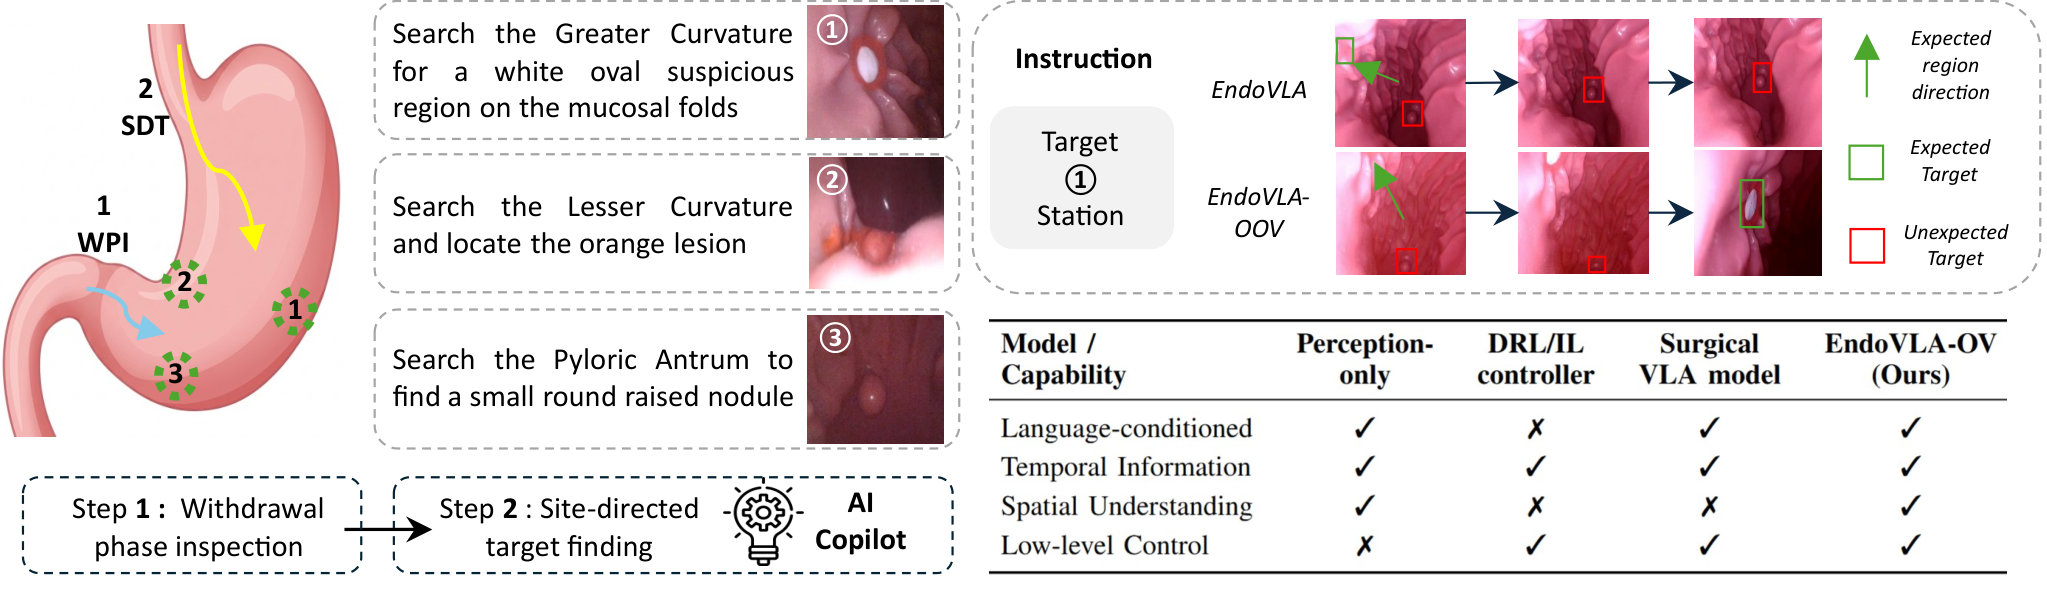
EndoVLA-OOV language-conditioned search and tracking for out-of-view targets.
Language & vision01

EndoVLA-OOV

Find what lies beyond the view.

Following a language instruction to find a target beyond the current field of view, then track it.
New · 2026Paper ↗
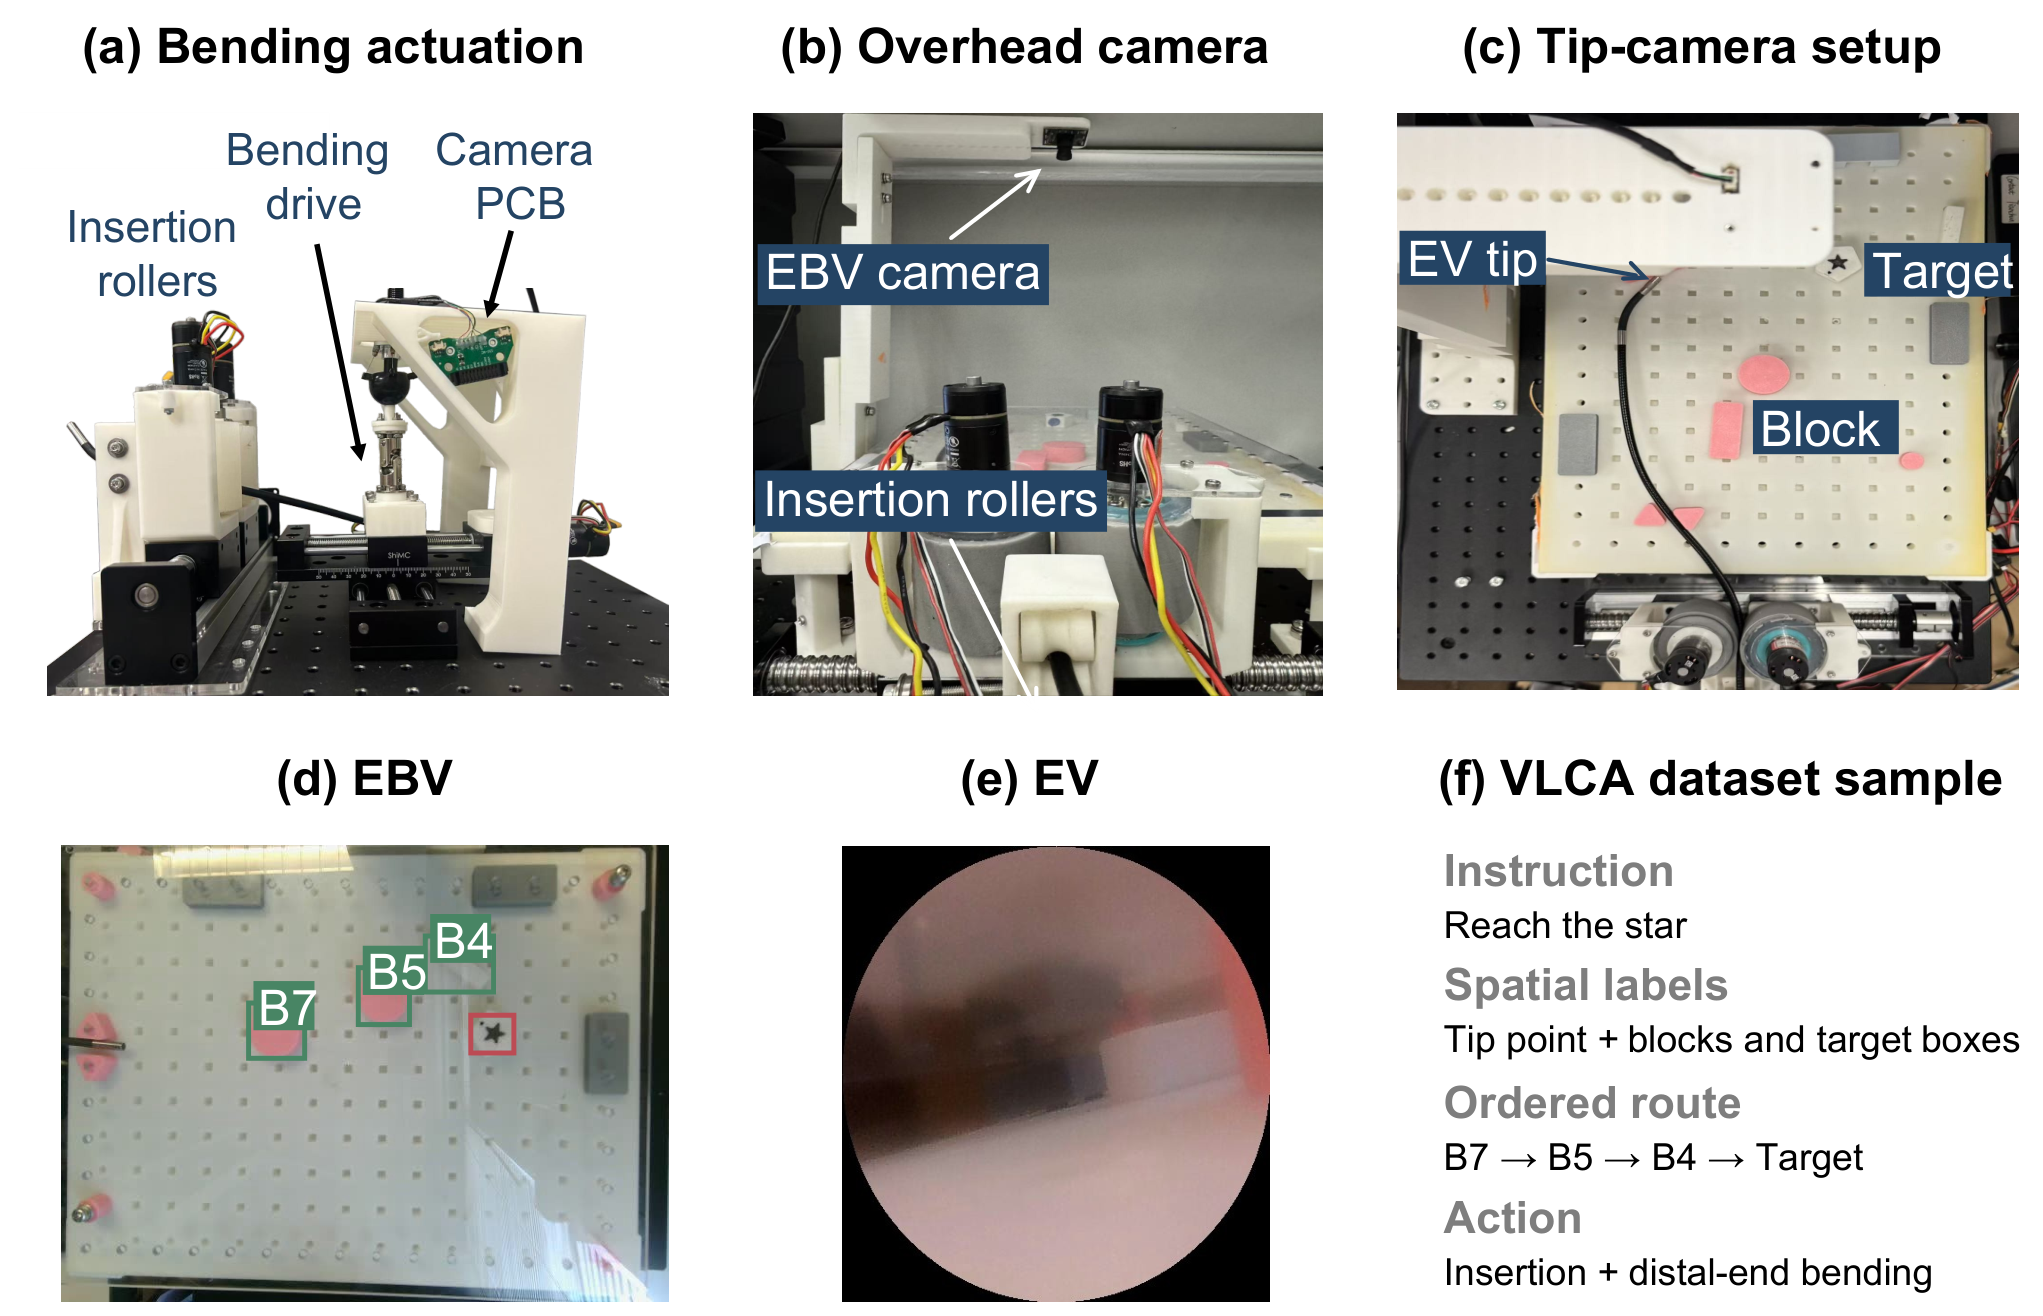
EBV-CAN robotic platform, bird’s-eye view and language-grounded navigation setup.
Contact-aided navigation02

EBV-CAN

A global view. A grounded path.

Grounding a target instruction in a global view to guide contact-aided endoscope navigation.

New · 2026Paper ↗
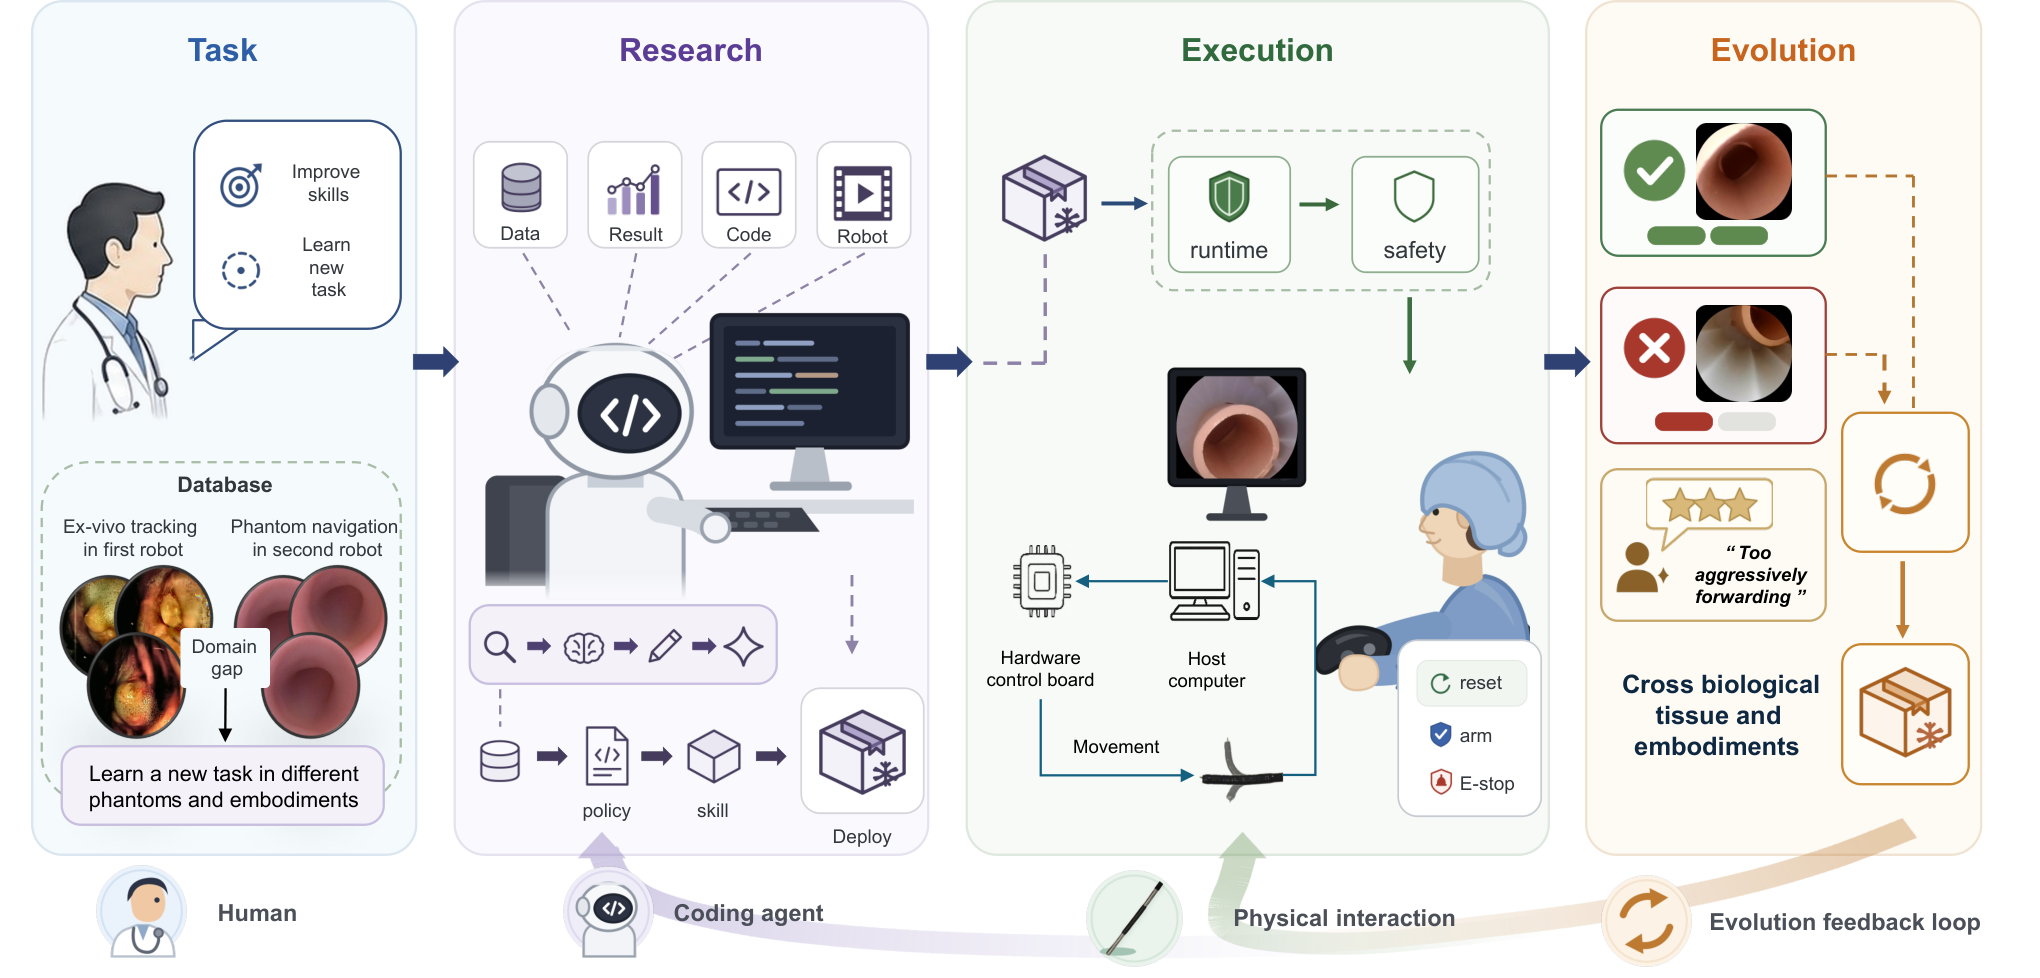
EndoRSI task, research, execution and evidence-driven policy improvement loop.
Recursive improvement03

EndoRSI

Let physical evidence guide the next policy.

Using physical outcomes and human feedback to recursively improve endoscopic robot policies.

New · 2026Paper ↗
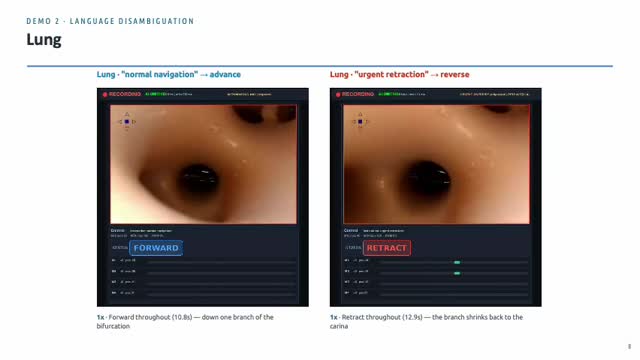
EndoLIFT uses language to distinguish advancing from retracting in the same visual scene.▶ Demonstration
Language & control04

EndoLIFT

The same view. A different intention.

One view, two possible actions: language selects forward navigation or urgent retraction.

Preprint · 2026Paper ↗
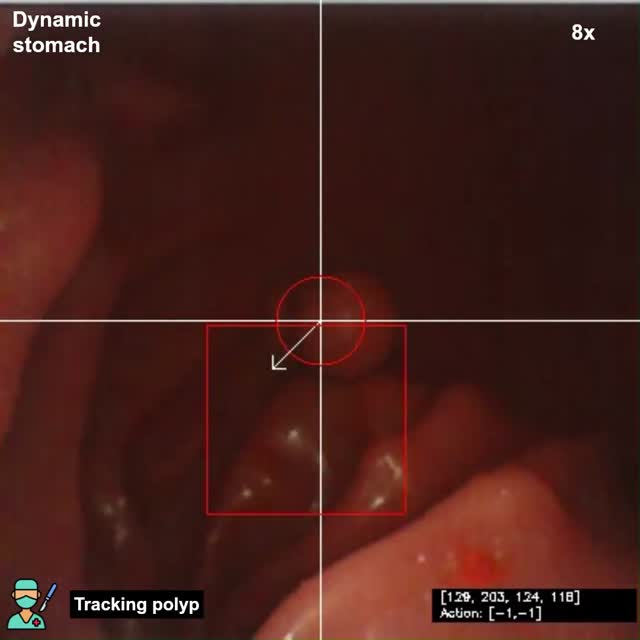
EndoVLA autonomous tracking driven by the surgeon’s instruction.▶ Demonstration
Vision-language-action05

EndoVLA

From an instruction to precise tracking.

Prompt-conditioned tracking of polyps, abnormal mucosa and circumferential cutting markers.

CoRL 2025 · SpotlightPaper ↗
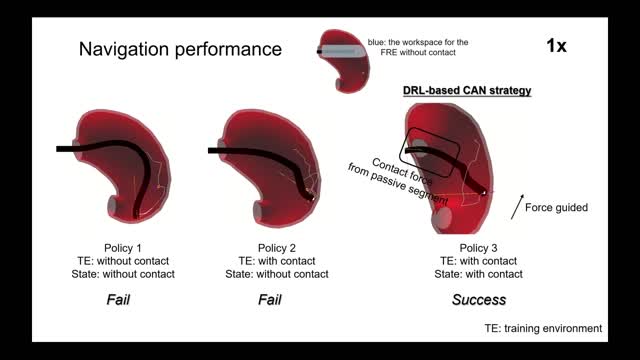
Contact-aided navigation of a flexible robotic endoscope in a deformable stomach.▶ Demonstration
Reinforcement learning06

CAN

Turning contact into a way forward.

Learning to use contact with a deformable stomach wall as guidance for navigation.

ROBIO 2025 · Best PaperPaper ↗

Make your next project count

Open Projects
@ CUHK EE

I’m happy to cooperate with CUHK EE undergraduates (including FYP), Summer Research Internship (SRI) students, and MSc students (course project or MSc project).

Let’s discuss an idea ↗

Example Topics (mix & match)

  • Reinforcement Learning
  • Recursive self-improvement agent
  • World model
  • Vision-language
02

Funded CUHK UG Summer Research Internship

See the official program for details.

Explore USRI ↗
03

CUHK International Summer UG Research Program

See the official program for details.

Explore SURP ↗
04

MSc projects

Scoped research and engineering topics aligned with your interests.

The people behind the work
Research is a team effort.

Meet REN Lab ↗
CUHK crest
Principal investigator

Hongliang Ren

REN Lab · Intelligent Medical Mechatronics
Department of Electronic Engineering, The Chinese University of Hong Kong
Get in touch ↗

Full author lists and contributions are provided on each project page.

Join the research

Build what
comes next.

One funded research assistant position is open for robot learning, continuum-robot control, and clinical phantom / ex-vivo experiments.

Apply by email ↗

HOW TO APPLY

  1. 01

    Send your CV and transcript to
    sharerpailab@gmail.com ↗

  2. 02

    Use this email subject:clinical01 funded RA application

  3. 03

    Candidates will be arranged a Zoom or face-to-face interview.

Affiliations
The Chinese University of Hong KongCU MedicineStanford UniversityTechnical University of MunichThe Sixth Affiliated Hospital, Sun Yat-sen University
Explore the related EndoWAM project ↗

Chi Kit Ng · CUHK

Get in touch.

For research, student projects and opportunities.

Open email app ↗