Physical-evidence-driven policy research 2026 · Preprint
EndoRSI
Physical-Evidence-Driven Recursive Improvement of Endoscopic Robot Policies
Every experiment informs what to try next.
01 / The idea
Every experiment informs what to try next.
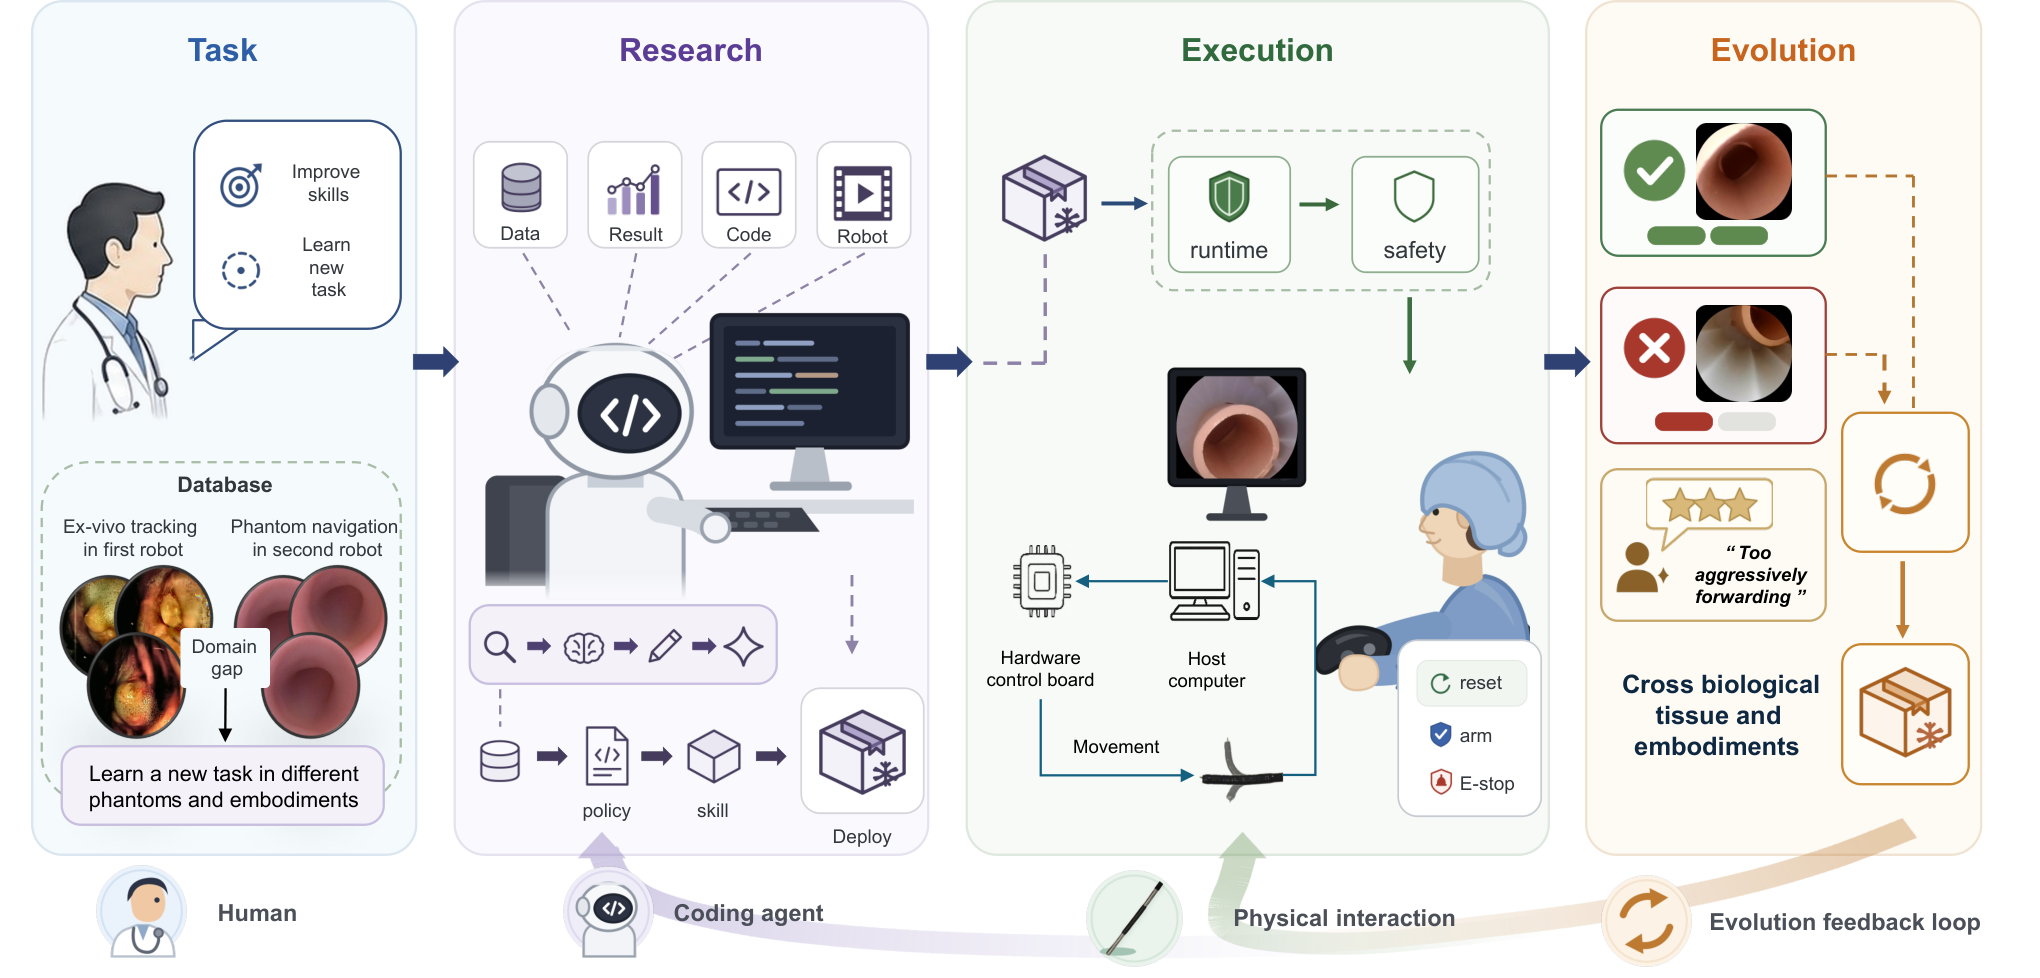
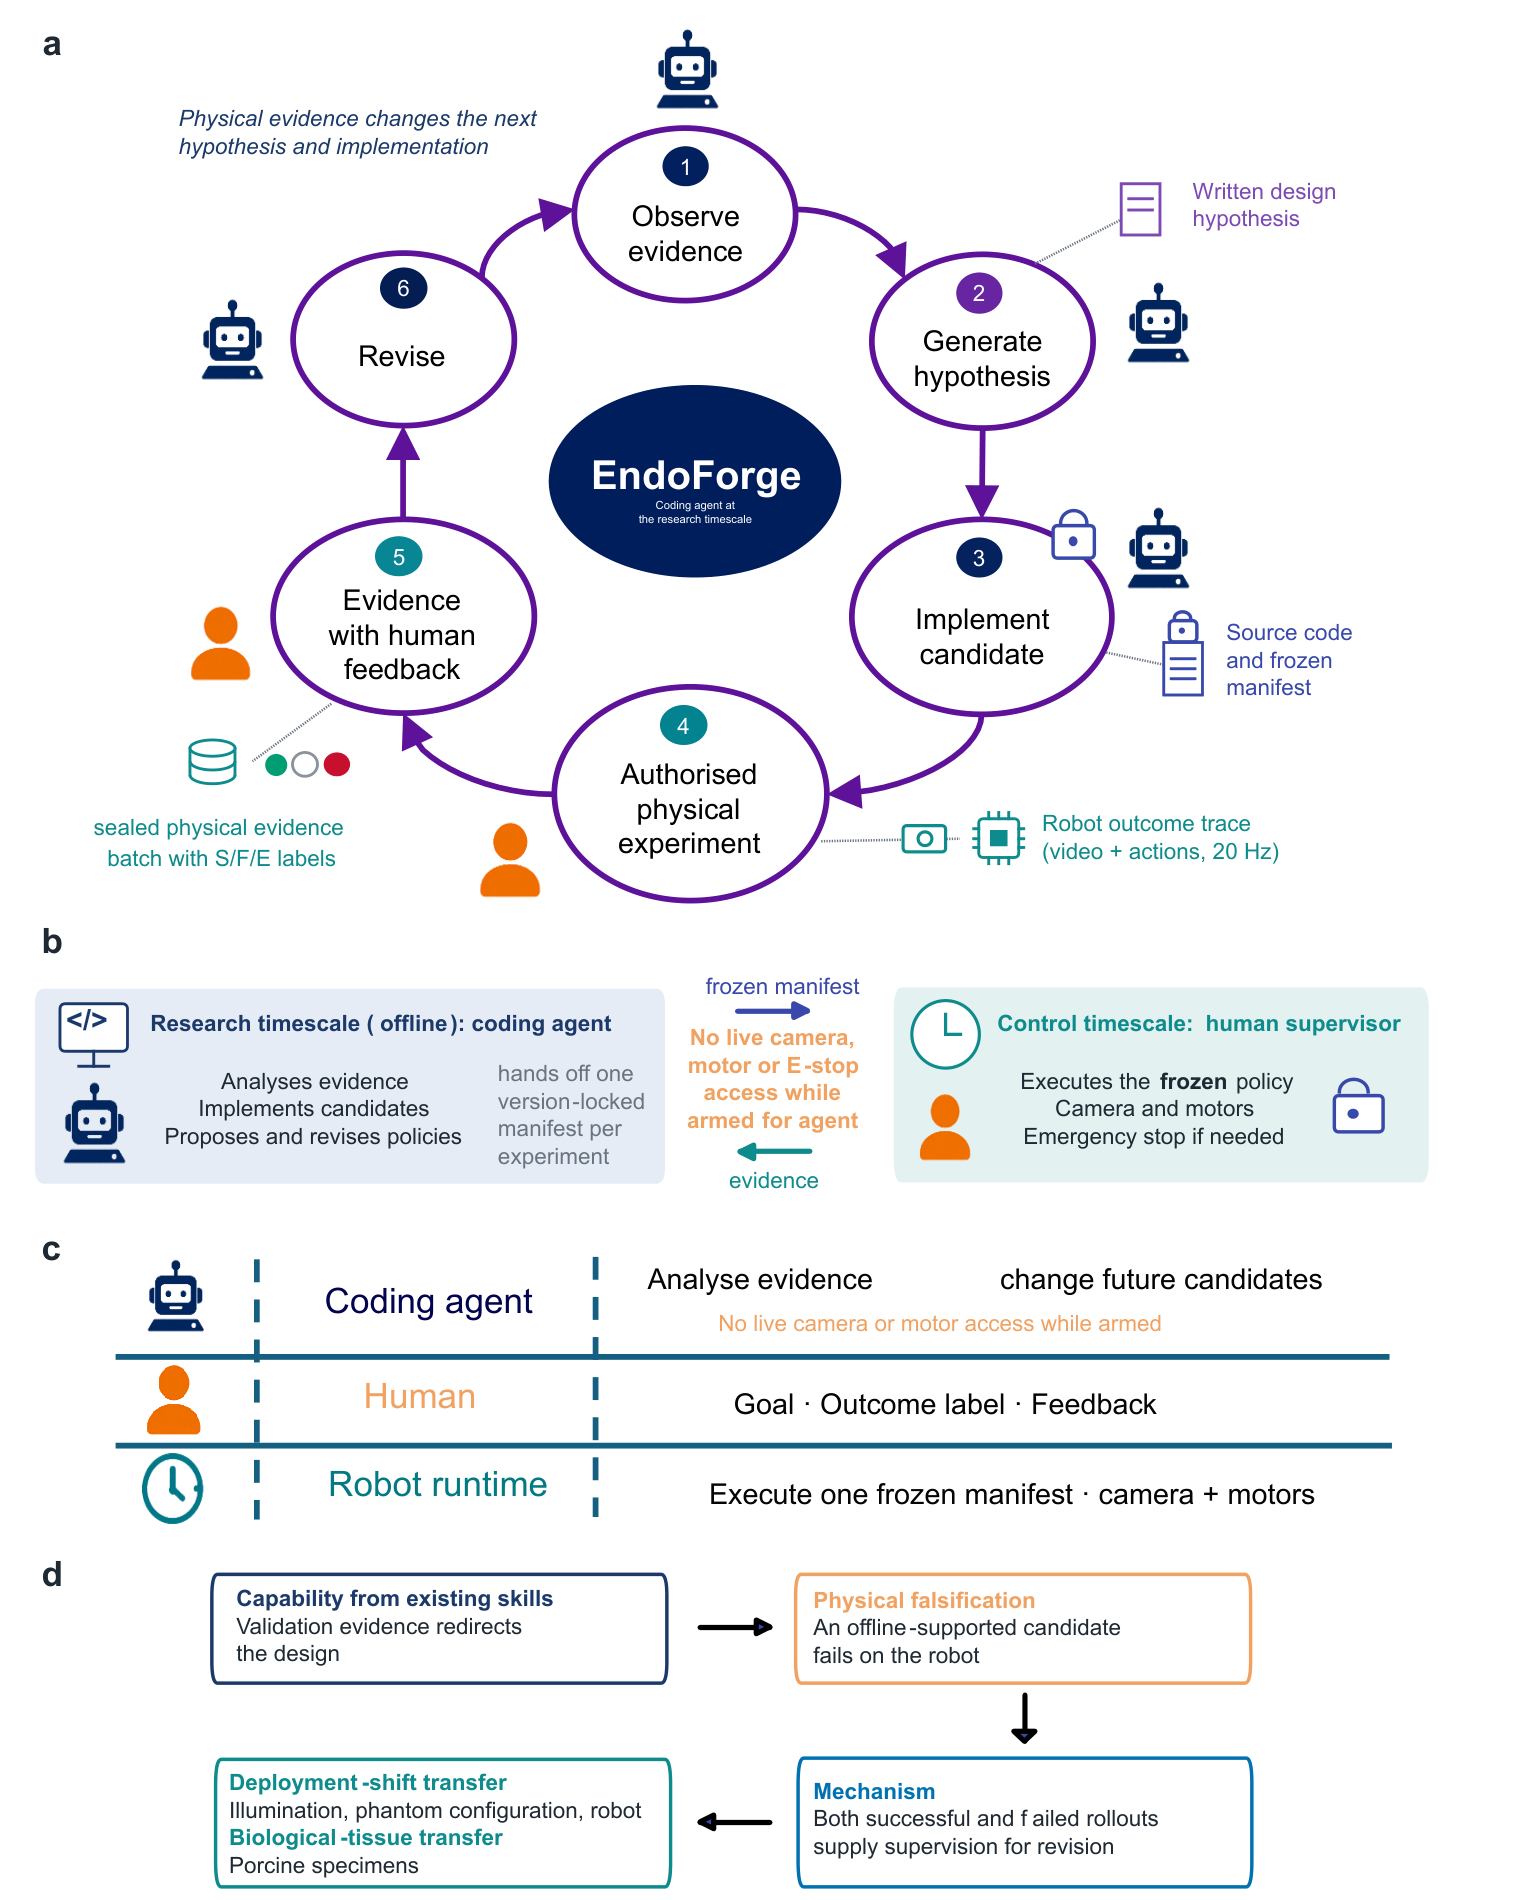
A coding agent analyses experiments and revises candidate policies. Human-authorised trials run in a separate safety-constrained runtime, and physical outcomes feed back into the next research cycle.
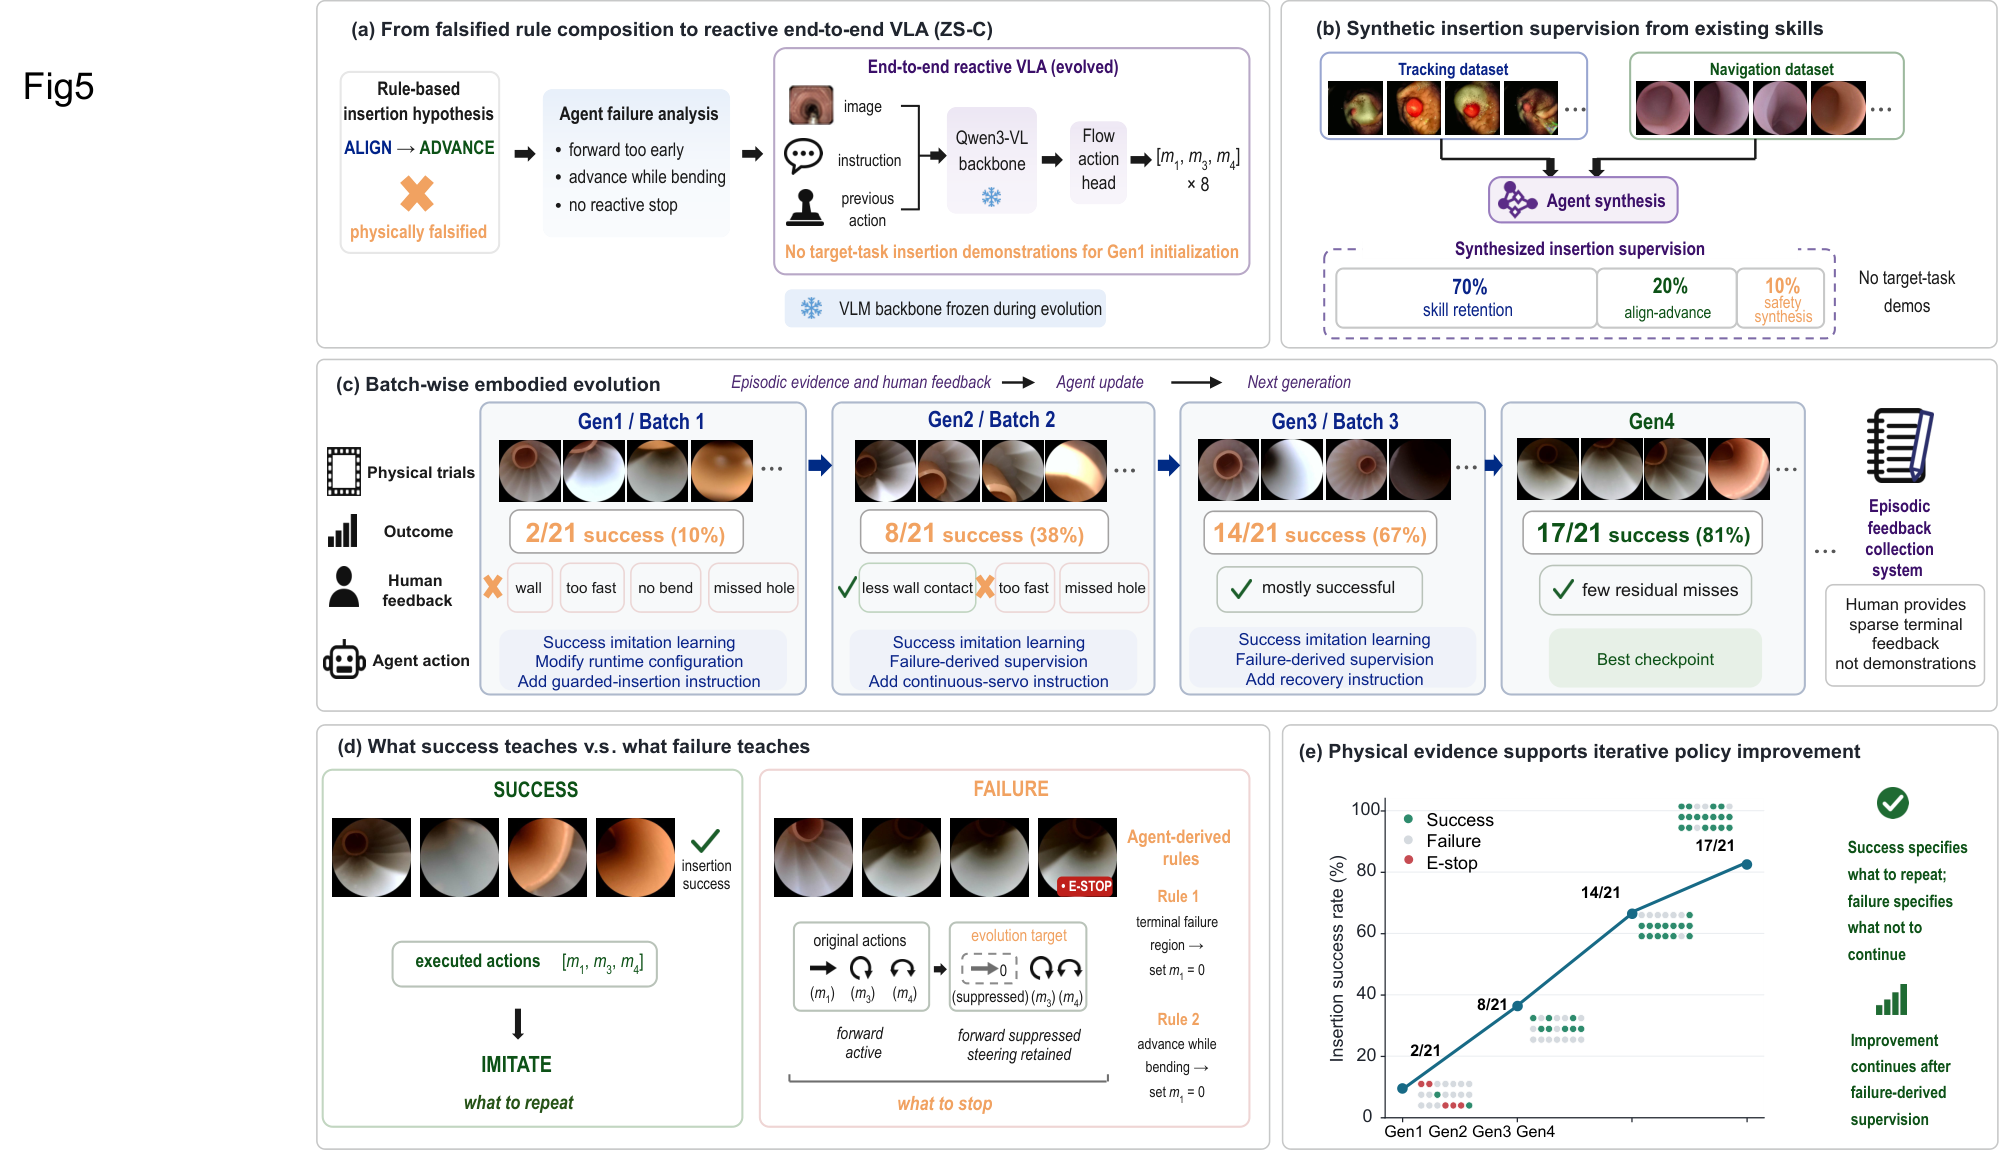
2 → 17insertion successes out of 21
4policy generations
6independent ex-vivo specimens
Insertion improves from 2/21 in generation 1 to 17/21 in generation 4. The final frozen policy is evaluated separately for transfer. Evaluation details ↗
02 / The approach
How it works
From observations to a physical outcome.
Propose & implement
The agent inspects evidence and develops a candidate policy.
Test under human control
An isolated runtime executes the authorised experiment.
Learn from outcomes
Failures and feedback shape the next policy revision.
03 / Physical evidence
Inside the experiments
04 / Reference
Build on this work
@misc{ng2026endorsi,
  title = {EndoRSI: Physical-Evidence-Driven Recursive Improvement of Endoscopic Robot Policies},
  author = {Chi Kit Ng and Yidong Zhang and Tianchun Wu and Siu Hing Lui and Hanlin Zhao and Huxin Gao and Hongliang Ren},
  year = {2026},
  eprint = {2610.13376},
  archivePrefix = {arXiv},
  primaryClass = {cs.RO},
  url = {https://arxiv.org/abs/2610.13376}
}